I am an MS Robotics student at Carnegie Mellon University, advised by Prof. David Held. Before joining CMU, I was an undergraduate researcher at UC Berkeley with Prof. Masayoshi Tomizuka.
My current research focuses on generalist policies for dexterous manipulation. I am working towards a future where robots can do anything humans can do, and more!
Joined the Robot Perceiving and Doing (RPAD) Lab at CMU, advised by Prof. David Held.
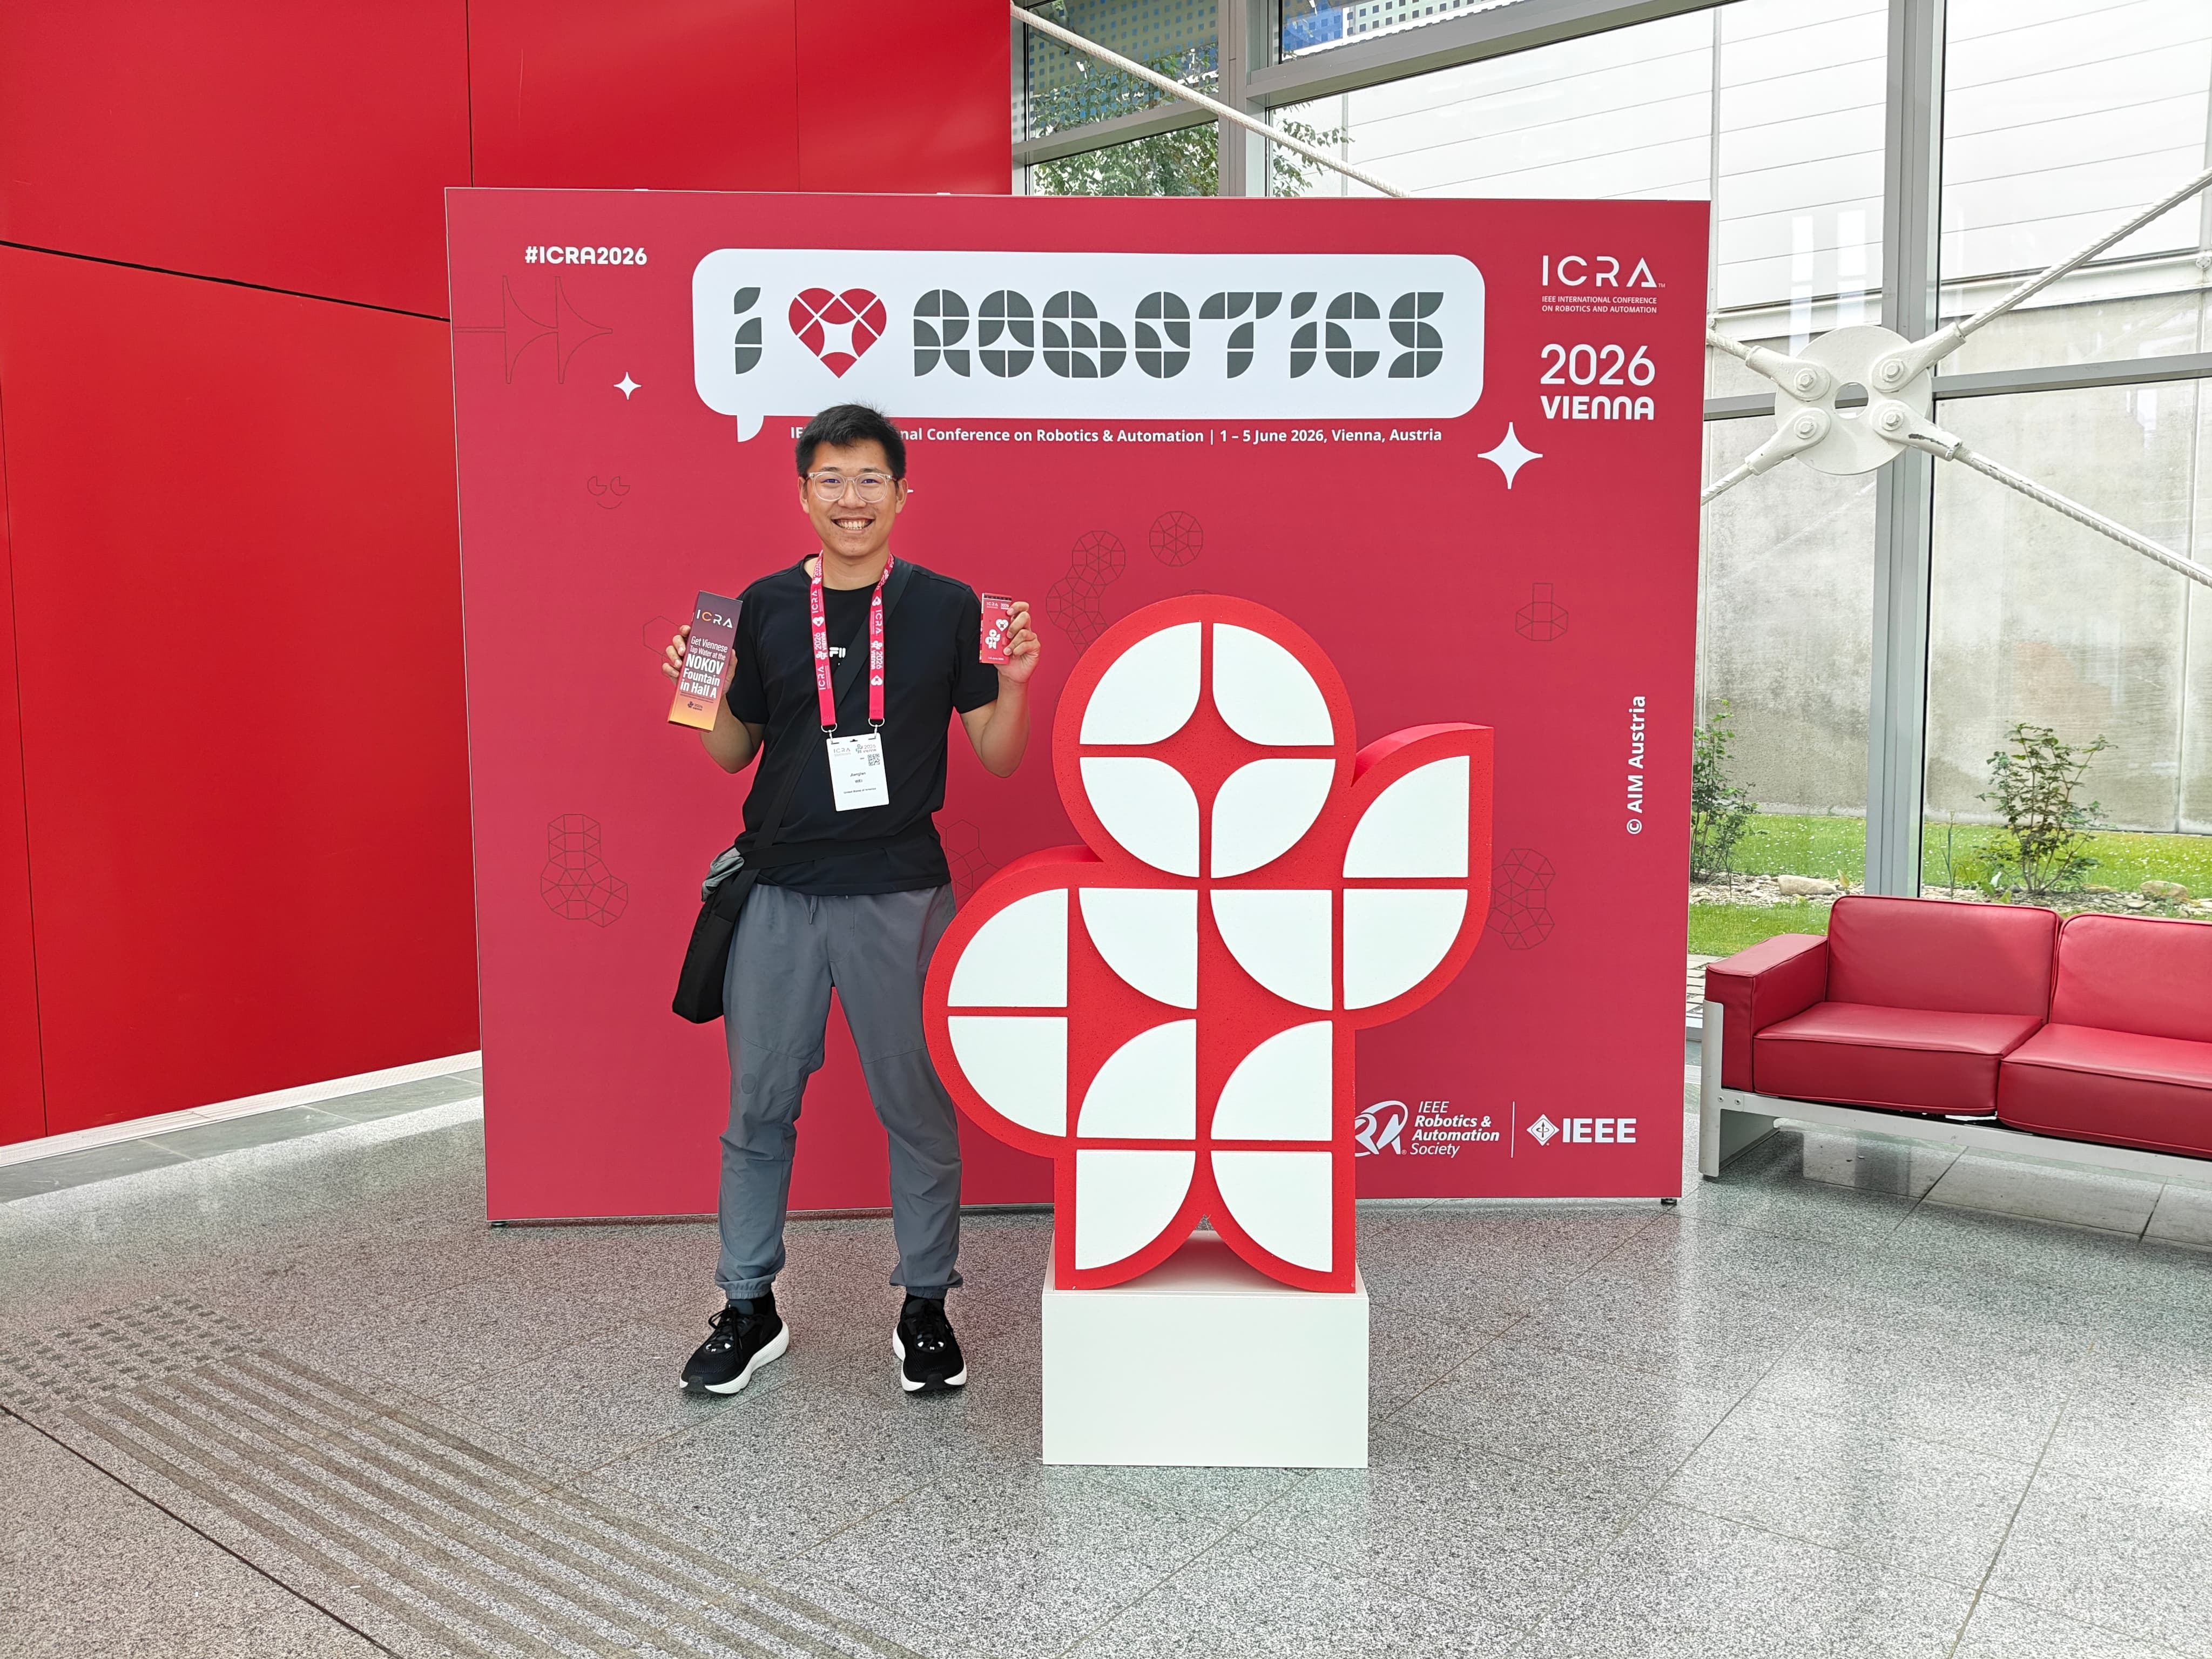
Attended ICRA 2026 in Vienna to present the ReOI World Model (photo).
Awarded the Chiang Chen Overseas Fellowship ($50,000) to support my graduate studies.
Invited to deliver the student address at the Berkeley Global Access closing ceremony.
Awarded the UC Berkeley BGA Scholarship 2024 (Top 10 students per term).
Won the National First Prize in the Contemporary Undergraduate Mathematical Contest in Modeling (CUMCM) 2024 (Top 0.5% among 59,278 teams).
Joined the Mechanical Systems Control (MSC) Lab at UC Berkeley, advised by Prof. Masayoshi Tomizuka (our photo).
IEEE International Conference on Robotics and Automation (ICRA),
Best Paper Finalist at
RSS Out-of-Distribution Workshop,
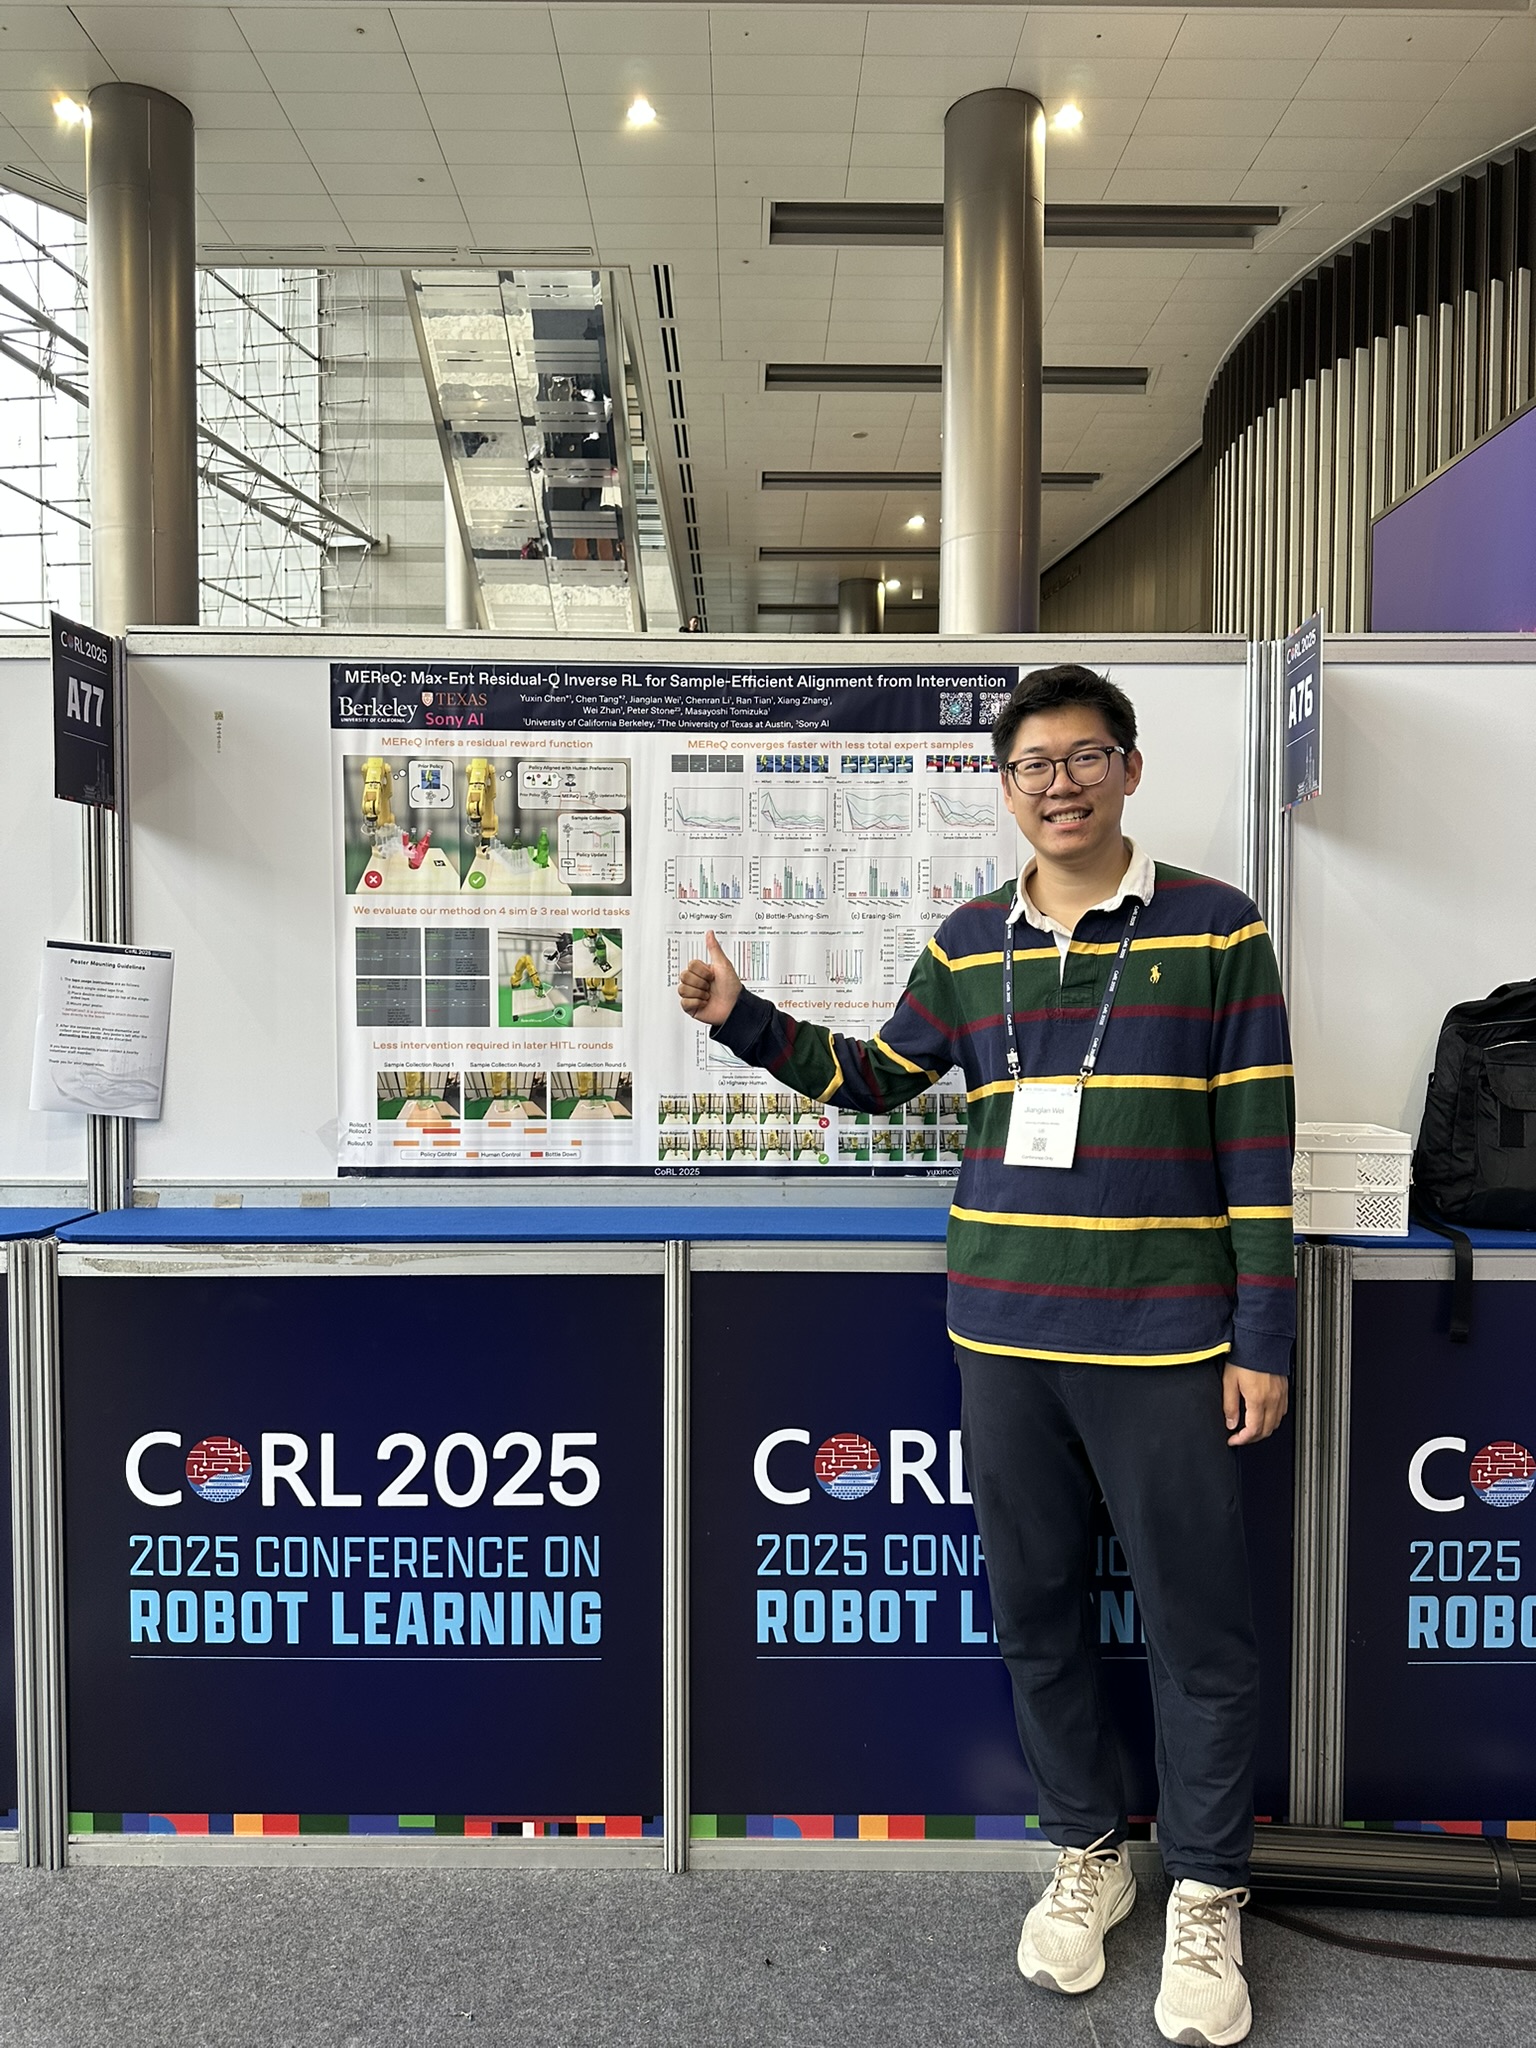
Conference on Robot Learning (CoRL),
International Conference on Learning Representations (ICLR),
CAAI International Conference on Artificial Intelligence (CICAI),
Neural Networks, Vol. 205
UC Berkeley CS180 taught by Prof. Alexei Efros (Fall 2024).
By chapter: coloring, blending, morphing, stitching, diffusion, NeRF
Final project for Autonomous Systems at HUST (Fall 2025).
I believe the best way to learn is by building projects and taking notes along the way. Most of my notes are adapted from existing tutorials with a different emphasis on the details. Here is a selection of my notes that are ready for sharing.